Franka Emika Panda Description (MJCF)
Requires MuJoCo 2.3.3 or later.
Overview
This package contains a simplified robot description (MJCF) of the Franka Emika Panda developed by Franka Emika. It is derived from the publicly available URDF description.
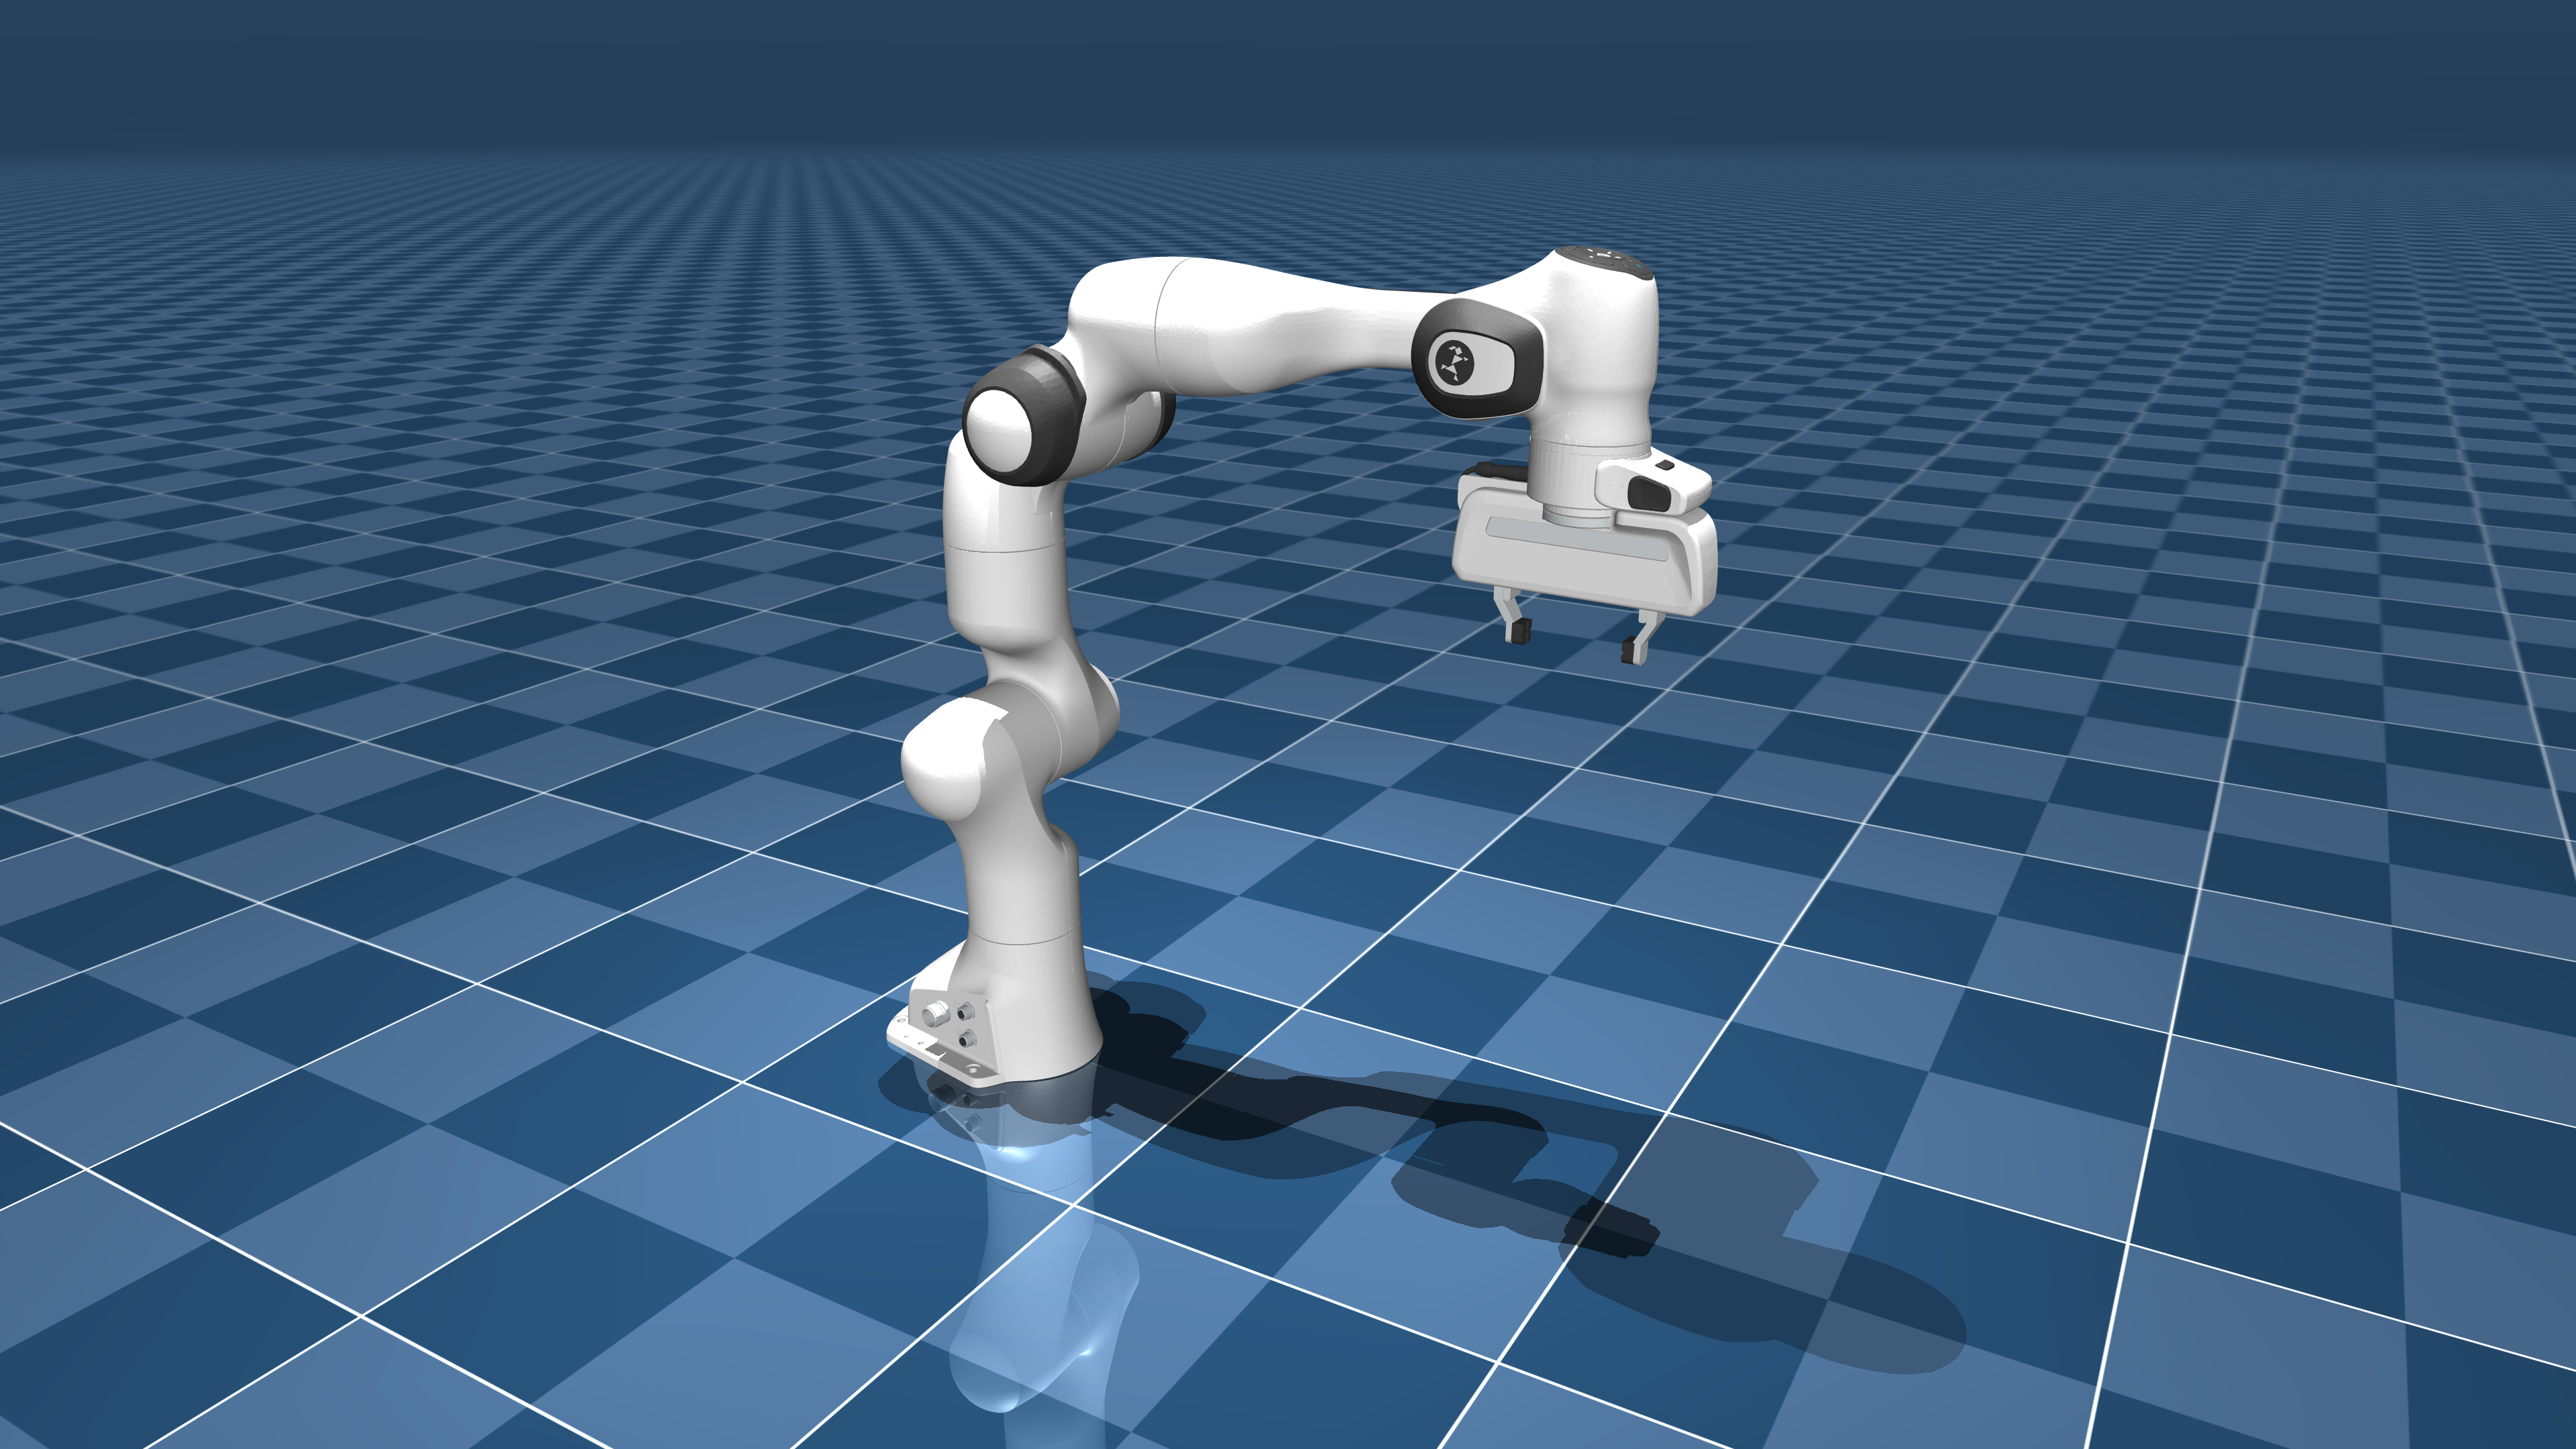
URDF → MJCF derivation steps
- Converted the DAE mesh files to OBJ format using Blender.
- Processed
.objfiles withobj2mjcf. - Eliminated the perfectly flat
link0_6from the resulting submeshes created forlink0. - Created a convex decomposition of the STL collision mesh
file
for
link5using V-HACD. - Added
<mujoco> <compiler discardvisual="false"/> </mujoco>to the URDF's<robot>clause in order to preserve visual geometries. - Loaded the URDF into MuJoCo and saved a corresponding MJCF.
- Matched inertial parameters with inertial.yaml.
- Added a tracking light to the base.
- Manually edited the MJCF to extract common properties into the
<default>section. - Added
<exclude>clauses to prevent collisions betweenlink7andlink8. - Manually designed collision geoms for the fingertips.
- Added position-controlled actuators for the arm.
- Added an equality constraint so that the left finger mimics the position of the right finger.
- Added a tendon to split the force equally between both fingers and a position actuator acting on this tendon.
- Added
scene.xmlwhich includes the robot, with a textured groundplane, skybox, and haze.
License
This model is released under an Apache-2.0 License.